Google Classroom
Google Classroom
GeoGebra
GeoGebra Classroom
Abrir sesión
Buscar
Google Classroom
Google Classroom
GeoGebra
GeoGebra Classroom
Esquema
MMT: Synthesis of Mechanisms
Synthesis of two angular follower's position with no quick return for a rocker's path ϴ4
Synthesis of two angular positions with no Quick Return
Synthesis of two positions for the coupler
Synthesis of a four bar for 3 posess
Synthesis of two angular position follower with Quick Retu
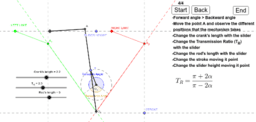
Synthesis of a slider crank with quick return
Synthesis of a Double 4-bar Quick Return
Synthesis of a 6 bar quick return slider crank
Synthesis of a Quick Return Mechanism
Synthesis of trajectory generation for 3 points in specified
Synthesis of 4 bar for 3 coupler's points
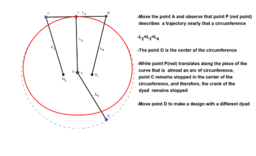
Single dwell with dyad
Single Dwell Mechanism with slider
Double rocker mechanism with dyad
MMT: Synthesis of Mechanisms
Autor:
Andereguillor
Synthesis of two angular follower's position with no quick return for a rocker's path ϴ4
Synthesis of two angular positions with no Quick Return
Synthesis of two positions for the coupler
Synthesis of a four bar for 3 posess
Synthesis of two angular position follower with Quick Retu
Synthesis of a slider crank with quick return
Synthesis of a Double 4-bar Quick Return
Synthesis of a 6 bar quick return slider crank
Synthesis of a Quick Return Mechanism
Synthesis of trajectory generation for 3 points in specified
Synthesis of 4 bar for 3 coupler's points
Single dwell with dyad
Single Dwell Mechanism with slider
Double rocker mechanism with dyad
Siguiente
Synthesis of two angular follower's position with no quick return for a rocker's path ϴ4
Nuevos recursos
Linear Equation Graphs: Thin Slice
Pythagorean Theorem: Extension Exercises
အခြေခံ data အခေါ်အဝေါ်များ
Slope Illustrator (2)
Function art 3D - waiting shed (v2)
Descubrir recursos
نظرية5
History and Technology
การบวกจำนวนเต็ม
Modul 9_SPLSV_Catur Fatmawati_SMPN 6 PPU
นาฬิกาเศษส่วนและทศนิยม
Descubre temas
Correlación
Hipérbola
Variables Aleatorias
Números Reales
Exponente